Awomo Takes the Top Two Spots on the MolmoSpaces Leaderboard
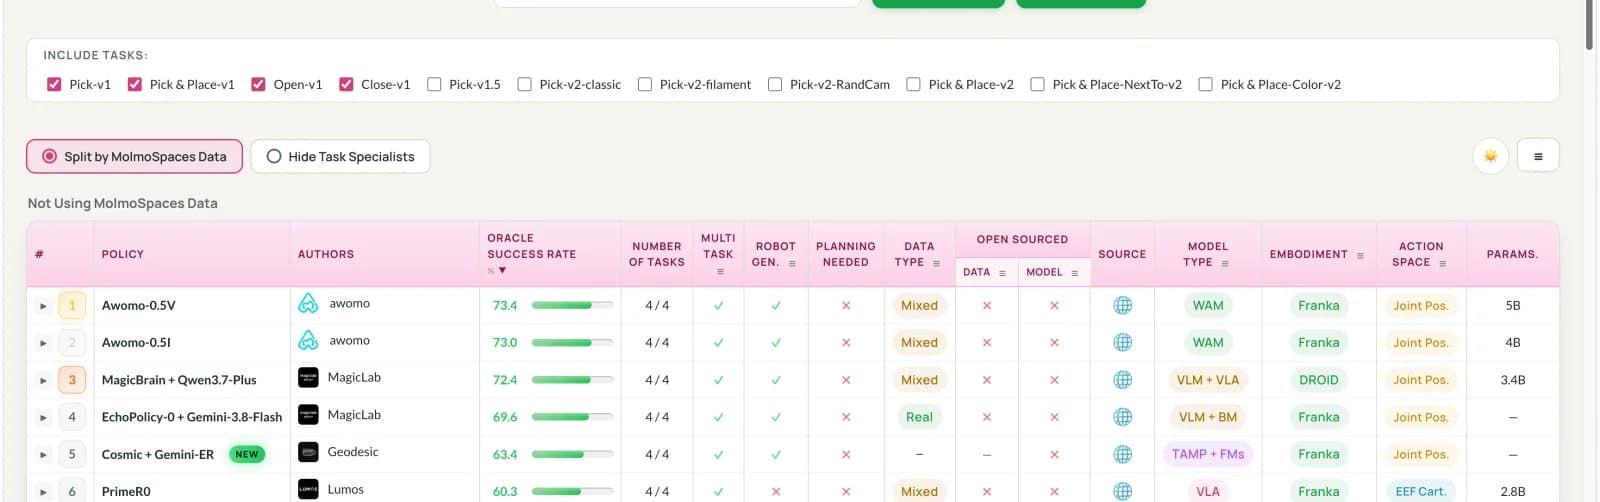
Awomo’s two world models, Awomo-0.5V and Awomo-0.5I, have achieved success rates of 73.4% and 73.0%, respectively, taking the TOP TWO spots on the MolmoSpaces leaderboard. The results highlight two models: one based on video generation and the other on image generation.
Evaluating Essential Manipulation Skills
MolmoSpaces evaluates robotic manipulation across diverse simulated objects and environments, testing how well learned skills generalize beyond familiar scenes. Both Awomo models were evaluated across four task categories: picking, pick-and-place, opening, and closing.
| Model | Success Rate | Rank |
|---|---|---|
| Awomo-0.5V | 73.4% | 1 |
| Awomo-0.5I | 73.0% | 2 |
Two Approaches to World Modeling
Awomo-0.5V generates future video sequences to capture how objects and environments change over time, deriving executable robot actions from these predicted sequences.
Awomo-0.5I predicts key future images, connecting current observations and task goals with anticipated outcomes to guide action decisions.
Their performance under the same evaluation protocol highlights the potential of both video-based and image-based world modeling for robotic manipulation.
From Future Prediction to Robot Action
Awomo continues to connect world modeling with robot action, advancing real-world validation toward more capable and reliable robotic systems.
Explore the MolmoSpaces leaderboard, and find Awomo on Hugging Face and GitHub.
Results and rankings reflect the leaderboard view shown for the four evaluated task categories as of October 13, 2026.